 haoran
A growing knowledge base for reading and understanding world-model research. The notes are written in Chinese, with complete paper explanations, comparisons across model families, and links to original sources.
Reading and connecting ideas
- Model-based reinforcement learning: Dreamer V1/V2/V3, RSSM, and latent imagination.
- Generative and interactive world models: Genie and the LingBot family, including latent actions and action conditioning.
- Research topics: action controllability, temporal credit assignment, and reinforcement learning for diffusion models.
- Code reading: EnerVerse-AC repository notes and source walkthroughs.
- Embodied policies: differentiable dynamics, unified world-action modeling, and video-based policy pretraining.
- Agentic control and adaptation: comparisons of native robot policies, policy harnesses, in-context demonstrations, and test-time training.
The repository also includes research questions, experiment plans, and scripts for building its paper index and checking content consistency.
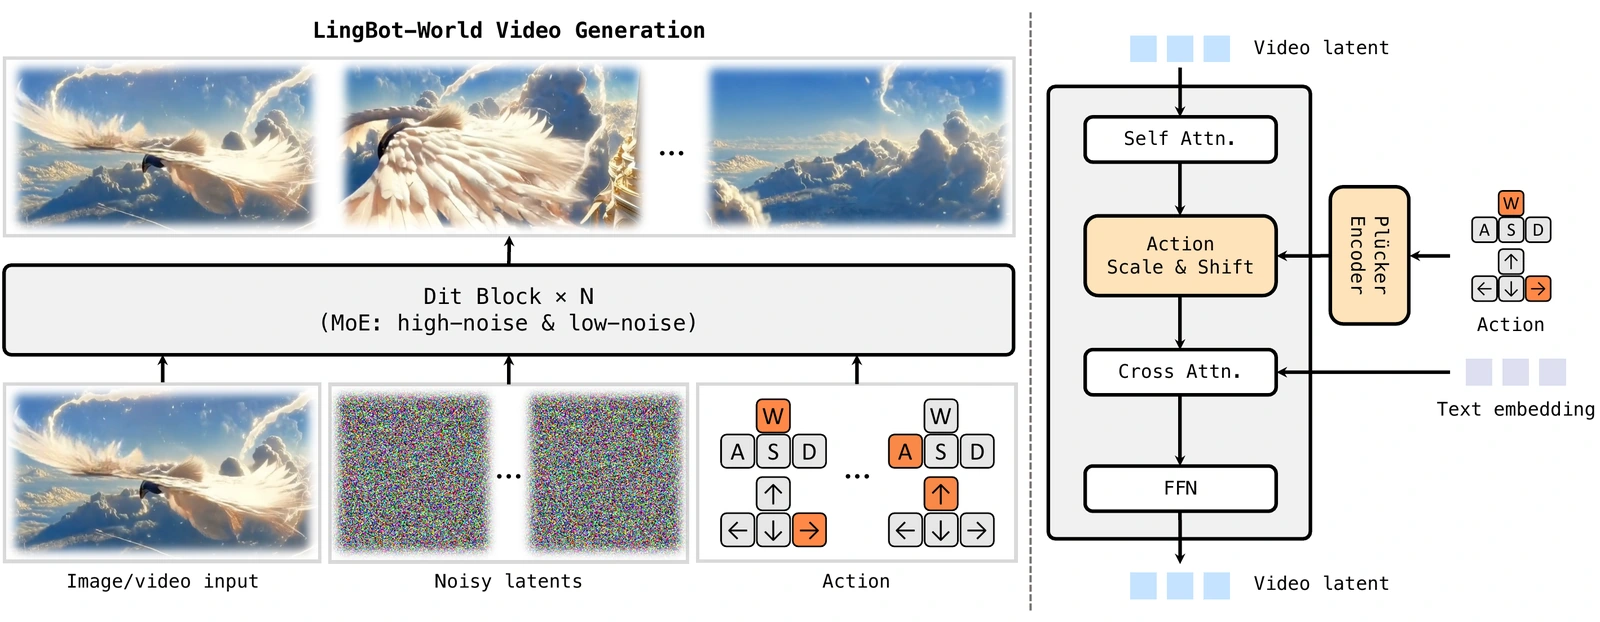
Cover image: Figure 5 from LingBot-World: Advancing Open-source World Models, Robbyant Team. This is a reference figure from a paper discussed in the notebook.
Originally hosted at UNIQUE-AILAB, the repository is now maintained under AetherNoah.